Power distribution
PowerLogic PDM
Ten-channel power distribution module with current monitoring and resettable electronic protection.
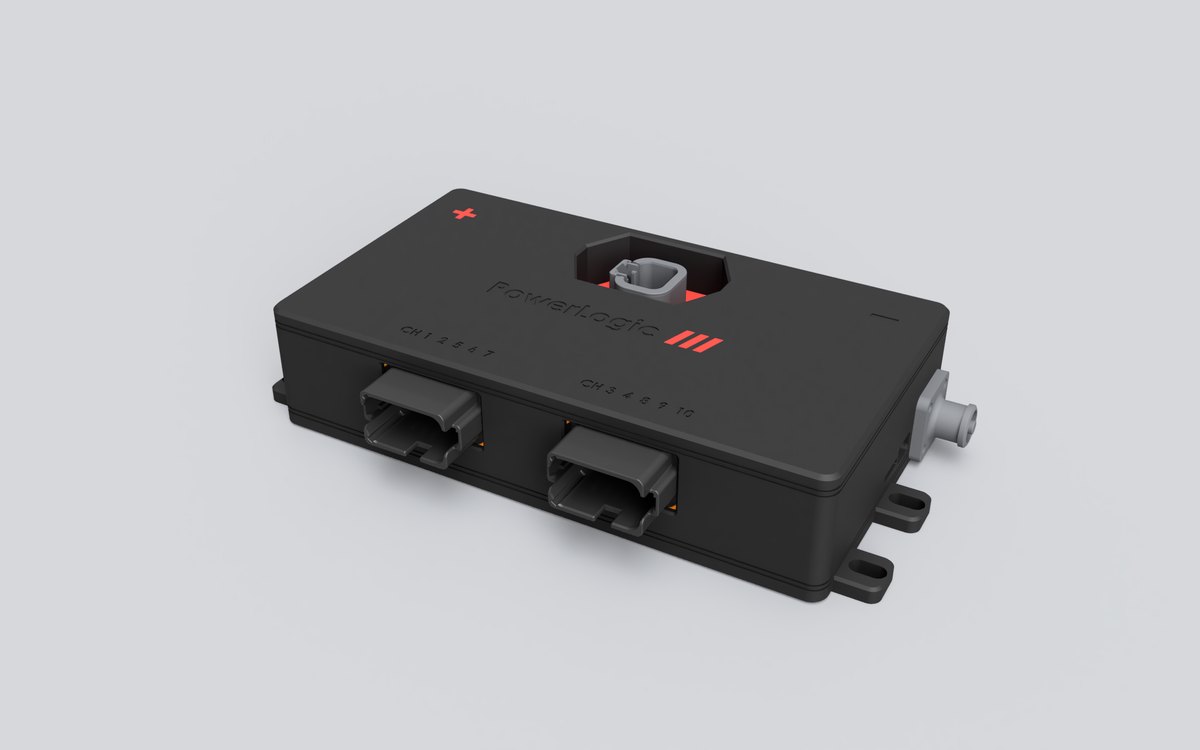
PowerLogic PDM enclosure with output headers, keypad port and SurLok battery terminal.
What it does
- Ten solid-state outputs replace fuses and relays, with the current on every channel monitored.
- Everything is controlled over CAN, from keypads or other modules, so there are no analog or switch inputs to wire.
- Bluetooth and microSD logging.
- Battery connections through SurLok Plus terminals at opposite ends, outputs through two Deutsch headers.
Specifications
| Outputs | Channels 1–4: 20 A. Channels 5–10: 15 A |
|---|---|
| Switches | Automotive-grade solid-state high-side switches |
| Battery | 2 × Amphenol SurLok Plus 5.7 mm |
| Output connectors | 2 × Deutsch DT13-12 |
| Keypad port | Deutsch DTP15-4P: 12 V, ground, CAN H, CAN L |
| Processor | 32-bit microcontroller with Bluetooth LE and CAN |
| Enclosure | 216 × 122 × 50 mm |
Pinout
PowerGroundCAN HCAN LOutputNot used
Output connector A
Deutsch DT13-12PA. Each output uses two pins.. Columns as they sit on the board.
- 1Output 5
- 2Output 6
- 3Output 1
- 4Output 2
- 5Output 7
- 6Spare
- 7Spare
- 8Output 7
- 9Output 2
- 10Output 1
- 11Output 6
- 12Output 5
Output connector B
Deutsch DT13-12PB. Each output uses two pins.. Columns as they sit on the board.
- 1Spare
- 2Output 8
- 3Output 3
- 4Output 4
- 5Output 9
- 6Output 10
- 7Output 10
- 8Output 9
- 9Output 4
- 10Output 3
- 11Output 8
- 12Spare
Keypad port
Deutsch DTP15-4P, mates with DTP06-4S. Pin positions are schematic.
- 1Keypad 12 V
- 2Ground
- 3CAN H
- 4CAN L
Battery terminals
Amphenol SurLok Plus 5.7 mm, red and black. One terminal at each end of the case.
- +Battery +
- −Battery −
Not to scale. Check the numbers molded on the connector before wiring. Pin colors only show each pin's function. They don't reflect the actual wire colors of any included pigtail.
Before you buy
- Blink keypads use a DTM04-4P connector, so they need an adapter lead.
- There is no ignition input: the module's run state comes from a keypad key or CAN command.